Noise and flow fields
This section has one path: learn how a flat grid becomes smooth directions, practice indexing and interpolation, then solve one tested flow-instrument problem.
- Lesson: turn a scalar grid into a flow field
- Practice: calculate, sample, and repair
- Exercise: create a tested coherent current
Lesson
Reveal an invisible field
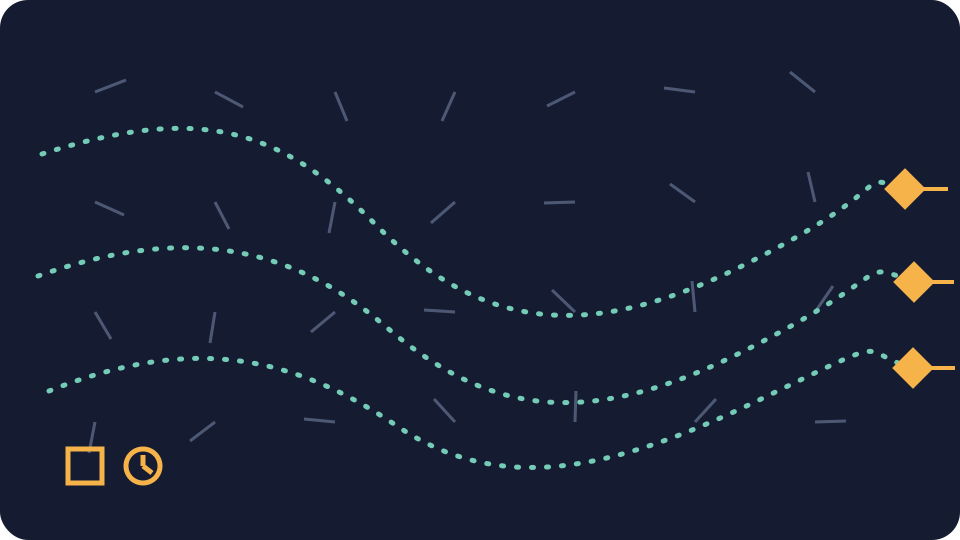
Nearby samples become smooth directions, then a limited group of particles reveals the field through trails.
A flow field is a grid of invisible arrows. A particle samples a nearby arrow and follows it, revealing the field as a trail. Pure random arrows would jerk between unrelated directions. Repeatable value noise supplies coherent corner values, and interpolation blends those values so nearby queries change smoothly.
Store two dimensions in one vector
A limited std::vector<float>
stores one scalar per cell in row-major order:
index = row * columns + column
Column 2, row 1 in a four-column grid has index 1 × 4 + 2 = 6. The helper
requires at least two rows and columns, checks coordinates and arithmetic, and
caps the field at 65,536 cells. A 256 × 256 field is legal; 257 in either
dimension is not. This checked flat vector is the section’s main C++ mechanism.
Value noise blends repeatable lattice values
Each integer (x, y, z, seed) corner receives the same 0-to-1 value on every
run. The lattice mixer credits the permissively licensed
Boost hash-combine pattern
and Chris Wellons’s public-domain
lowbias32 work
.
The bundled expression retains its
third-party notice
.
Between integer corners, each fractional coordinate uses smoothstep:
smooth(t) = t * t * (3 - 2 * t)
Eight corner values are interpolated along x, then y, then z. This lesson uses value noise rather than Ken Perlin’s gradient-noise implementation; the creator’s noise reference provides context, not copied code. Spatial scale controls how quickly the field changes across the grid. Temporal scale and time rate separately control what region of time is sampled and how quickly time advances.
Bilinear sampling blends four stored cells
Particles sample the stored viewport grid at normalized x and y. Four neighbors are mixed:
upper = lerp(top_left, top_right, tx)
lower = lerp(bottom_left, bottom_right, tx)
value = lerp(upper, lower, ty)
The bilinear interpolation reference
shows the same four-corner structure. A 2 × 2 grid with rows 0, 1 and 1, 0
samples to 0.5 at (0.5, 0.5). Normalized 0 and 1 select the first and last
row or column exactly; x == 1 is valid. Out-of-range, non-finite, malformed,
or stale grids reject without changing output.
Noise interpolation is trilinear because the source varies in x, y, and time. Stored-grid sampling is bilinear because that grid has only x and y. Keeping the stages separate makes each calculation testable.
Map one scalar to one direction
A scalar s becomes an angle and unit vector:
angle = clamp(s, 0, 1) * 2*pi
direction = {cos(angle), sin(angle)}
Scalar 0.25 gives pi/2 and approximately (0, 1). Scalar 0.125 gives
approximately (0.7071, 0.7071), proving that both vector components matter.
Particles advance by direction * advection_speed * fixed_dt.
Centers wrap through the radius-aware visible interval. A wrap resets that particle’s oldest-to-newest history to its new point so the renderer cannot draw a false line across the window. Reduced motion keeps only the current point. Particle count, grid cells, histories, and catch-up work have hard caps.
The bounded accumulator follows the fixed-step rule : invalid time is rejected, long frames are clamped, whole unprocessed steps are counted as dropped, and only a substep remainder is retained. P pauses, M clears histories, T freezes field time while particles continue, and R restores all repeatable state.
Pointer, drag, and arrows adjust the same visible field-coordinate offset through the openFrameworks event adapter . The renderer reads model state; it does not own the only copy of any tested value. Exact integer hash rows are pinned, while derived floating-point values use explicit tolerances rather than claiming cross-GPU pixel identity.
Practice
Practice is guided and has no unit-test gate. Calculate one index and boundary sample, inspect the independent oracle, run the instrument, and repair one row-major mistake.
1. Calculate row-major and bilinear cases
Draw a 3 × 3 grid containing 0.0 through 0.8 in row-major order. In a
three-column grid, column 2, row 1 is flat index 5. At normalized (0.5, 0.5),
both scaled coordinates equal 1, so the bilinear sample is the center cell 0.4.
At (1, 0.5), x selects the final column and y the middle row, so the answer is
0.5.
For the 2 × 2 grid from the Lesson, work through the two horizontal lerps before
the vertical lerp. Then map its center value 0.5 to angle pi and direction
approximately (-1, 0).
2. Inspect the independent oracle
Linux or macOS:
cat exercises/11-noise-and-flow-fields/fixtures/flow-oracle.txt
Windows Developer PowerShell:
Get-Content .\exercises\11-noise-and-flow-fields\fixtures\flow-oracle.txt
Find the exact integer hash rows, bilinear center 0.5, and quarter-turn vector
(0, 1). Distinguish the pinned integer values from the tolerance-checked
derived floats.
3. Run the flow instrument
Set OF_ROOT to openFrameworks 0.12.1. Linux or macOS:
scripts/section-11.sh generate --project starter
scripts/section-11.sh build --project starter --configuration Release
Launch exercises/11-noise-and-flow-fields/starter/bin/starter on Linux, or
open the generated .app on macOS. Windows Developer PowerShell:
.\scripts\section-11.ps1 generate -Project starter
.\scripts\section-11.ps1 build -Project starter -Configuration Release
& .\exercises\11-noise-and-flow-fields\starter\bin\starter.exe
Move the field-coordinate control with pointer and arrows. Compare P with T: pause stops particles and field time, while freeze keeps particles moving through one static field. Try R, M, every edge, wrapping, and a tiny window.
4. Repair swapped grid indexing
In exercises/11-noise-and-flow-fields/shared/flow_field_model.cpp, temporarily
change:
index = row * columns + column;
to:
index = column * rows + row;
Rebuild and run the non-square starter grid. Nearby arrows now come from the wrong stored cells. Restore the row-major formula and confirm the coherent current returns. If this was your only intended edit:
git restore -- exercises/11-noise-and-flow-fields/shared/flow_field_model.cpp
That command discards every uncommitted change in the named file. Square grids can hide this mistake, which is why the practice app uses unequal dimensions.
Exercise
Problem: create a coherent-current instrument
Create a materially different field drawing by choosing parameters in
starter/src/design/flow_field_design.cpp and geometry or trail grammar in
starter/src/ofApp.cpp. Preserve checked row-major access, two explicit
interpolation stages, scalar-to-angle mapping, distinct spatial and temporal
controls, seed identity, finite guards, fixed-step dropped-time accounting,
work caps, wrap behavior, keyboard access, reset, and reduced motion.
Use the coherent-current instrument exercise brief as the authoritative source for editable files, controls, constraints, fixtures, and the explained solution.
Run the unit tests
Linux or macOS:
CXX=g++ tests/run-section-11-tests.sh
CXX=clang++ tests/run-section-11-tests.sh
Windows Developer PowerShell:
.\tests\run-section-11-tests.ps1
The suite checks pinned integer hashes, row-major indexing and caps, malformed grids, bilinear known cases and exact edges, non-finite rejection, scalar-to-unit vector cases, deterministic generation, fixed-step partitions and dropped time, field-time freeze, radius-aware wrap and history reset, reduced motion, reset, work limits, and learner design ranges. Build starter and solution in Debug and Release, then launch both; tests never compare renderer pixels.
Quick visual check
- Pointer, drag, and arrows change the same visible field-coordinate control.
- P pauses without a burst, R replays, M removes histories, and T freezes field time while particles continue.
- Head geometry or ticks communicate direction when trails are reduced.
- Frozen and live state use shape rather than color alone; nothing flashes.
- Resize, every edge, radius-aware wrapping, and tiny viewports remain safe.
- Grid scale, temporal response, density, geometry, memory, composition, and palette differ from both examples.
- Text and palettes have suitable contrast; alt text names coherence, direction, time state, history, wrapping, controls, and shape roles.
- Reused references, code, and assets remain credited.
If you get stuck
If the field looks like static, inspect two neighboring grid values and the two lerp amounts before touching particle motion. If particles fly away, freeze time and draw direction ticks, then inspect angle mapping, bounds, and fixed-step input. Making the invisible grid visible usually turns a mysterious flow bug into one wrong index or number.